M.S. Robotics · Carnegie Mellon University
I’m interested in scaling robot data and designing efficient frameworks and algorithms for robot learning.
I’m a Master of Science in Robotics student at CMU’s Robotics Institute, working with Prof. Deva Ramanan on robot learning. My recent work, MimicAgent, turns natural-language prompts into reference motions for dynamic quadruped skills.
Previously, I was a research assistant in RISLab with Dr. Wennie Tabib and a research intern in the STOCH Lab at IISc Bangalore with Dr. Shishir N. Y. Kolathaya. I hold B.Tech and M.Tech degrees in Aerospace Engineering from IIT Kanpur, where I worked on multi-UAV mapping with Dr. Indranil Saha.
Research & selected work
Projects
Robot learning, human-centered autonomy, and 3D vision.
MimicAgent
Quadruped Skills via Prompt-to-Trajectory Generation
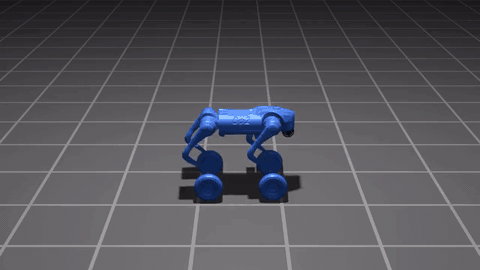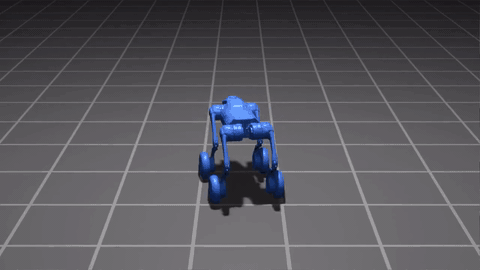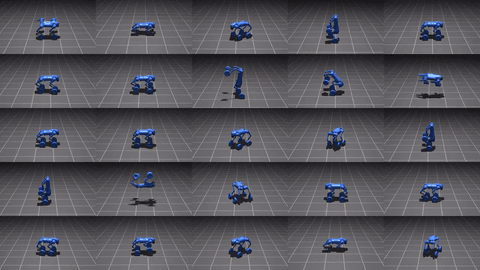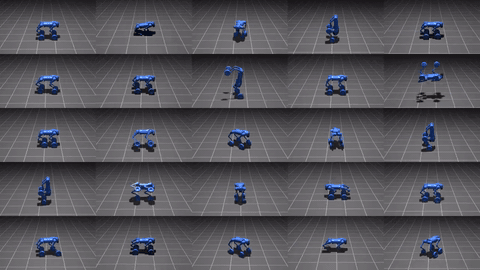
MimicAgent uses coding agents to turn a natural-language skill prompt into a coarse reference trajectory. Example-guided reinforcement learning then trains a dynamic quadruped policy that can run in simulation and on a real robot.
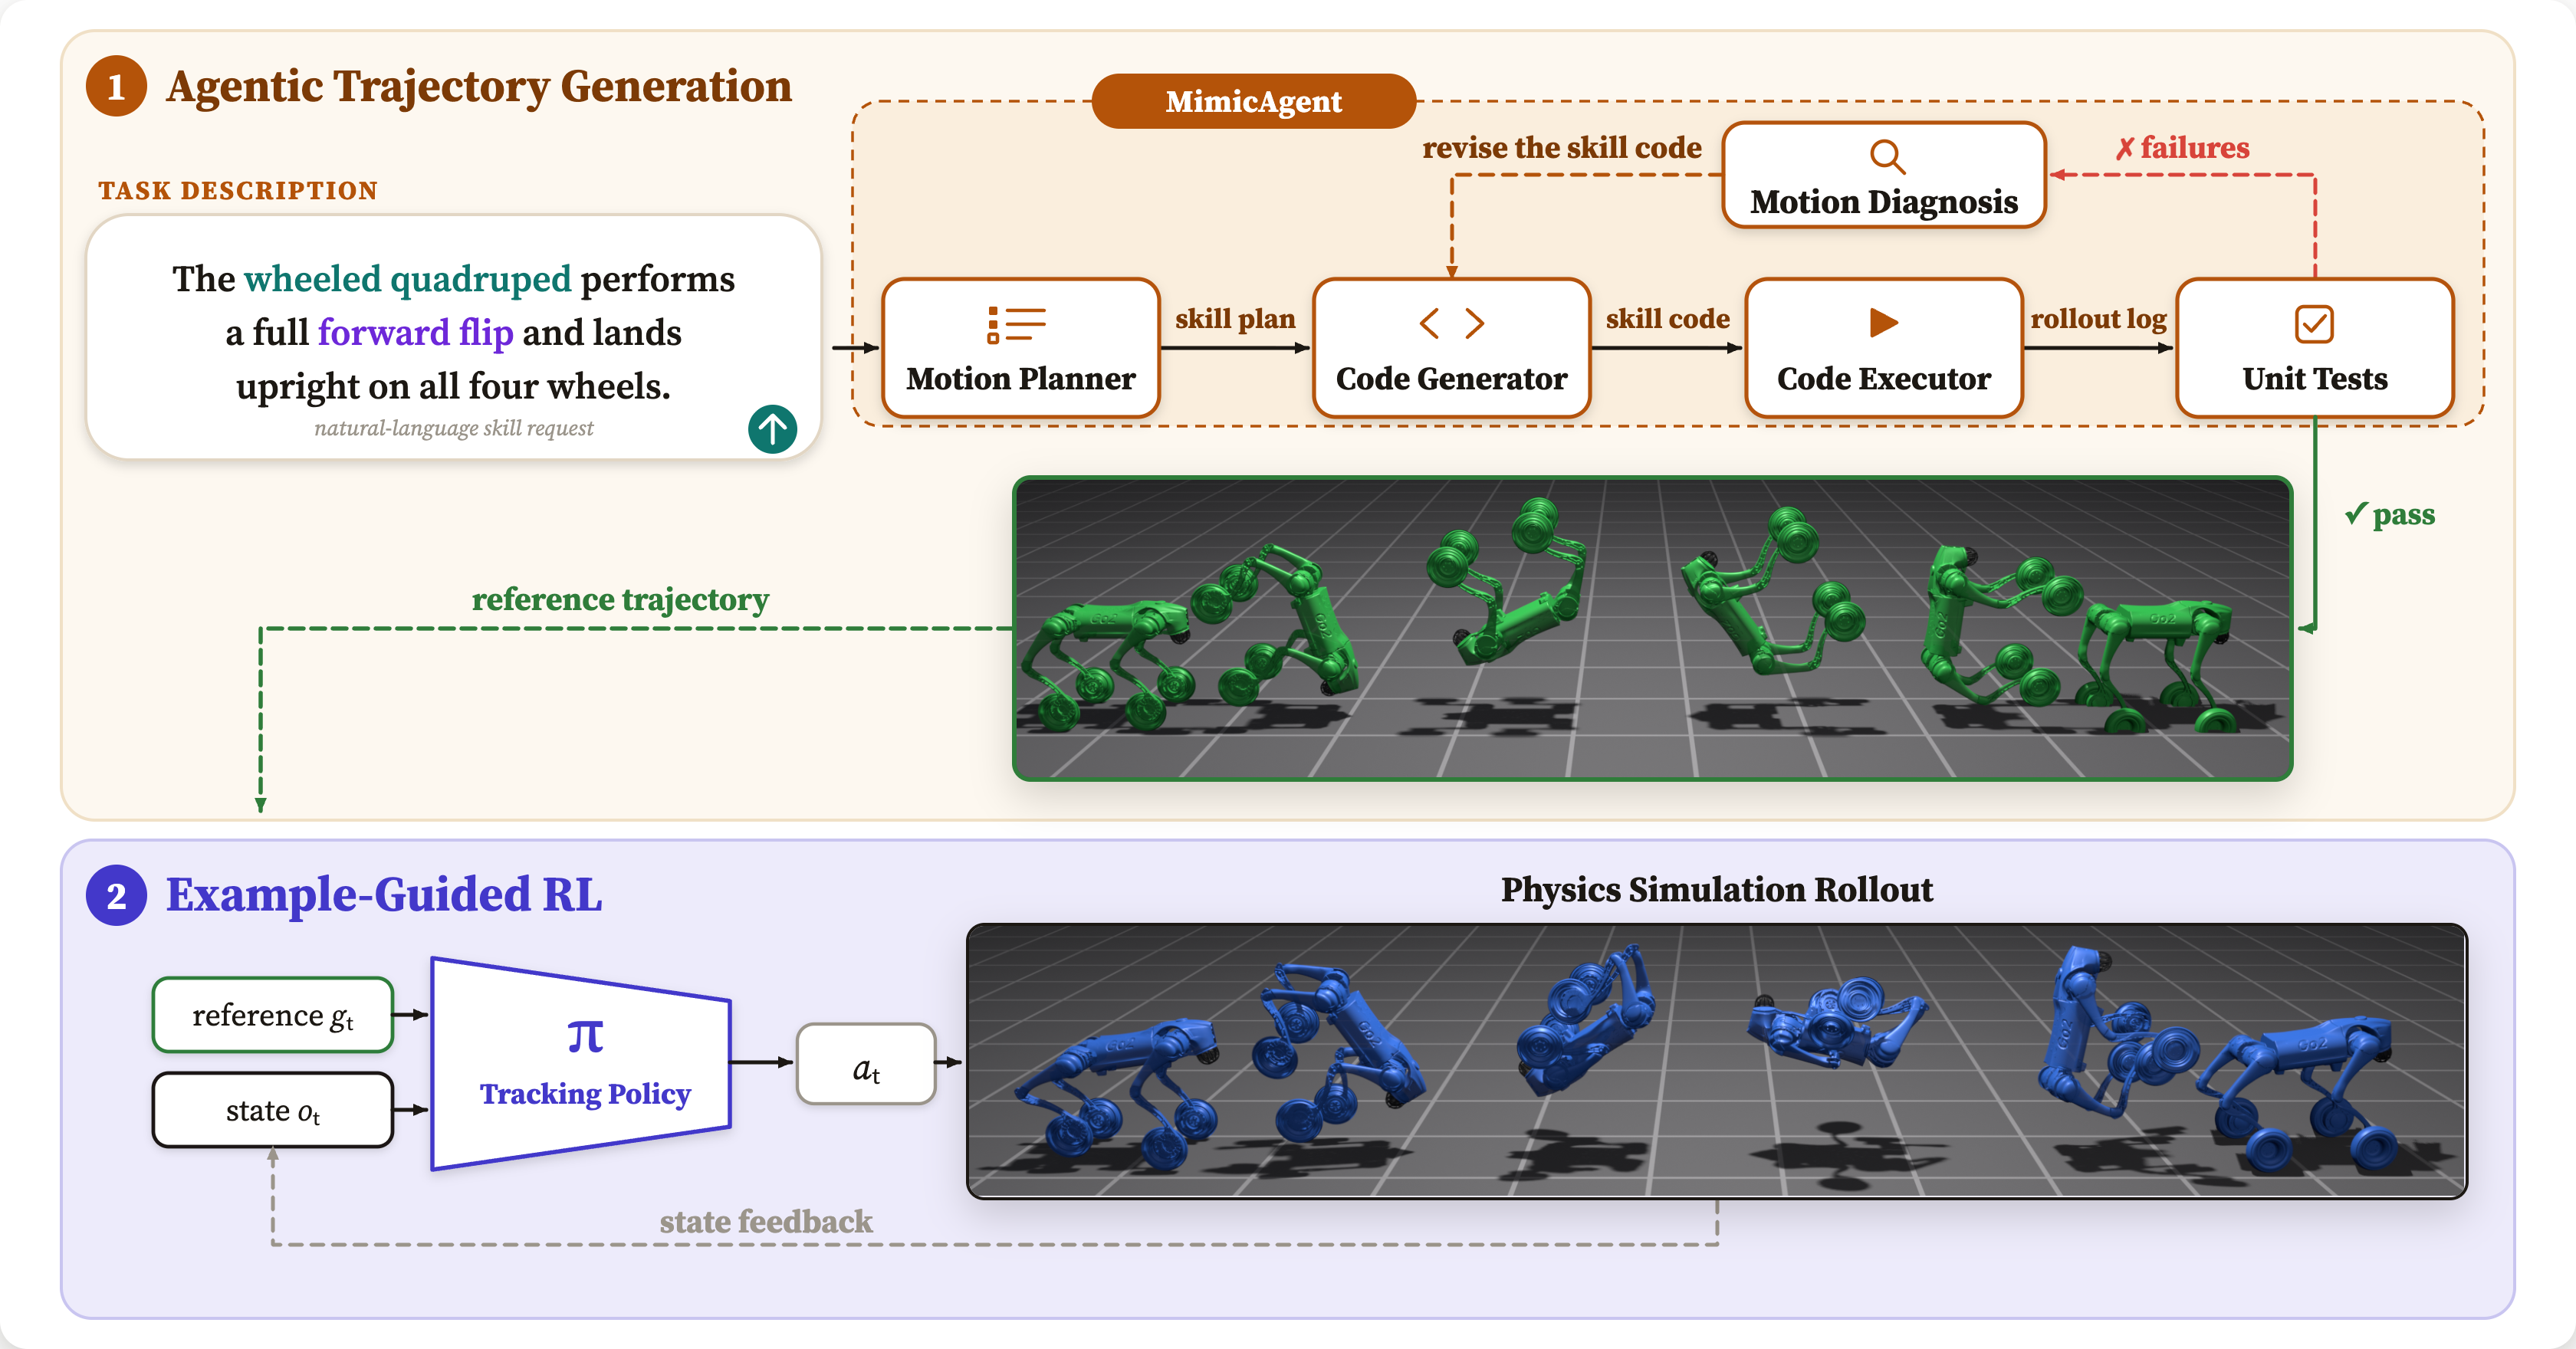
Spotlight at the IROS 2026 AI Meets Autonomy workshop · Published at the ICLR 2026 Workshop on Recursive Self-Improvement
VIP: VLM-Guided Interactive Policy Steering
Test-Time Preference Alignment
A vision-language model compares candidate robot trajectories against a person’s preferences and asks a visually grounded question when uncertain. In the report, natural-language feedback improves alignment with fewer interruptions than manual trajectory selection, while conversation history reduces repeated questions.
With Shikun Ban, Shohei Nagai, and Zixi Song.
Geometry-Aware Multi-View Diffusion
Enhancing Multi-View Diffusion with Geometry-Aware Positional Encoding
We add RayRoPE to EscherNet’s diffusion model for novel-view generation. The geometry-aware encoding improves image quality over camera-only encoding on DL3DV. We also study whether learned uncertainty tracks generation error, view visibility, and depth error.
With Minsik Jeon and Chaneui Song.
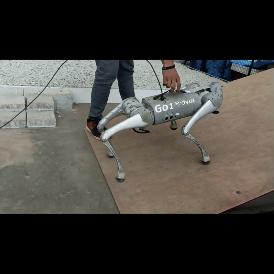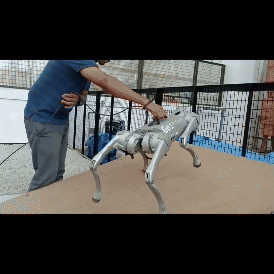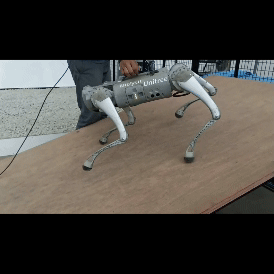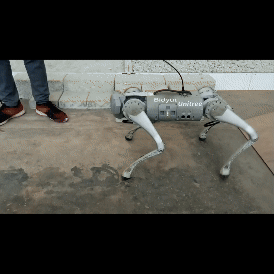
Quadruped Locomotion Control
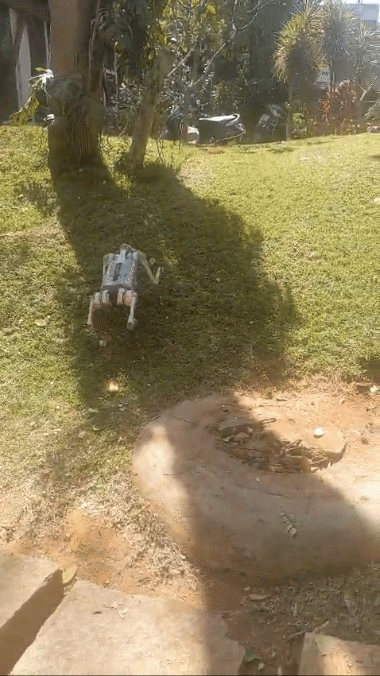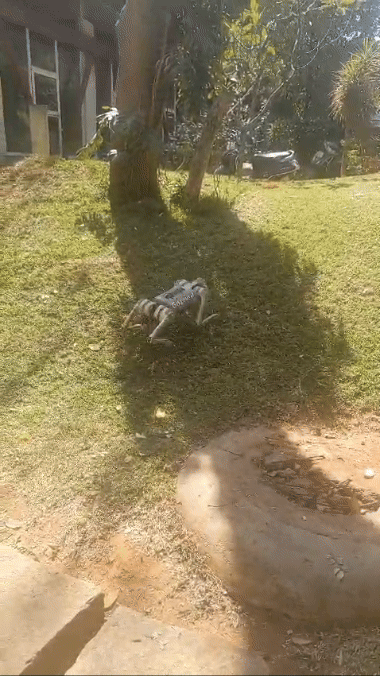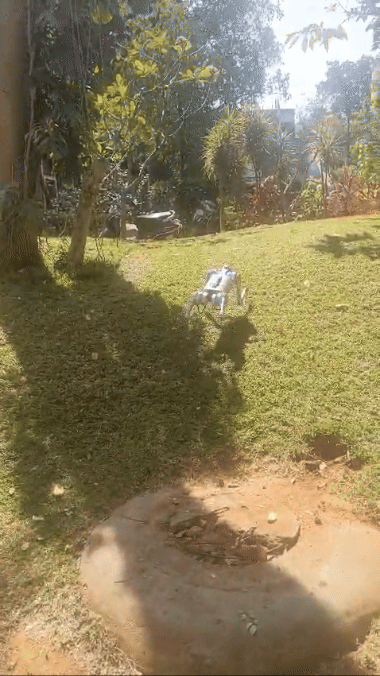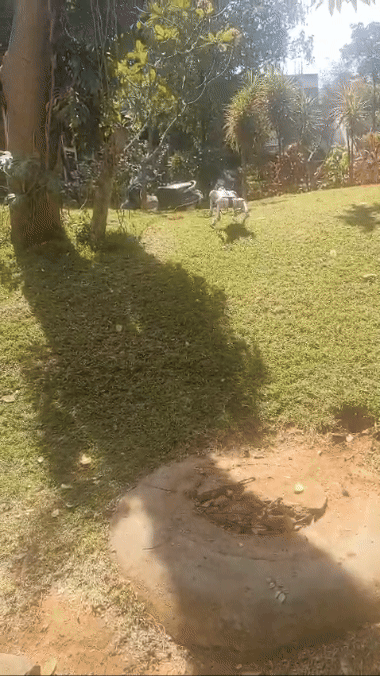
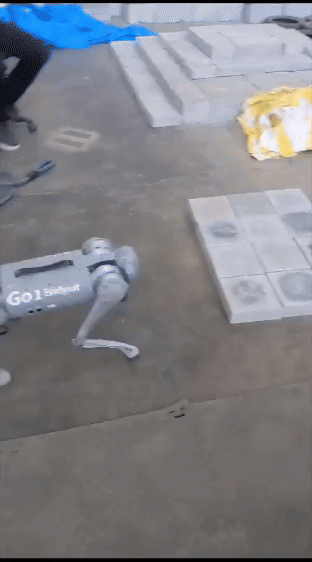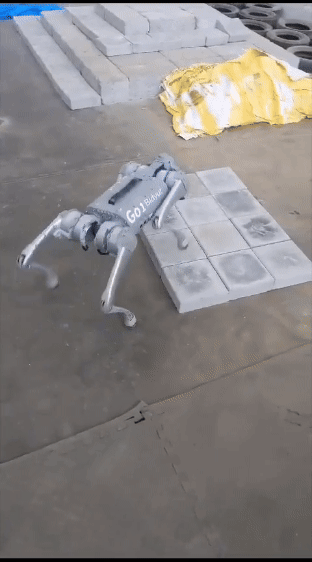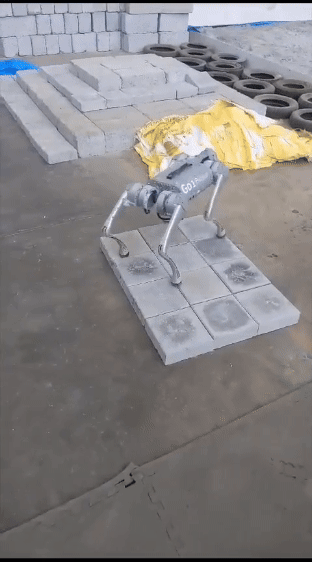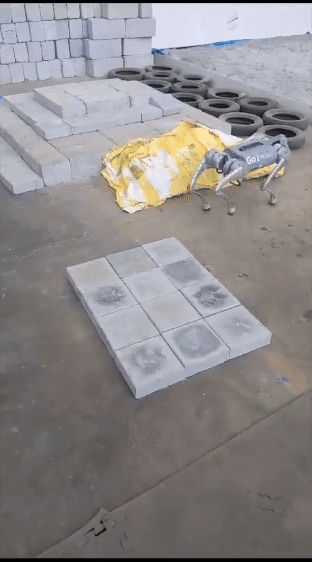
Developed a hierarchical reinforcement learning controller for quadruped locomotion across slopes and varied surfaces. Contributed to a ROS 2 controller stack designed to work across robots and controllers.
Aerial Mapping with Multi-UAV Systems
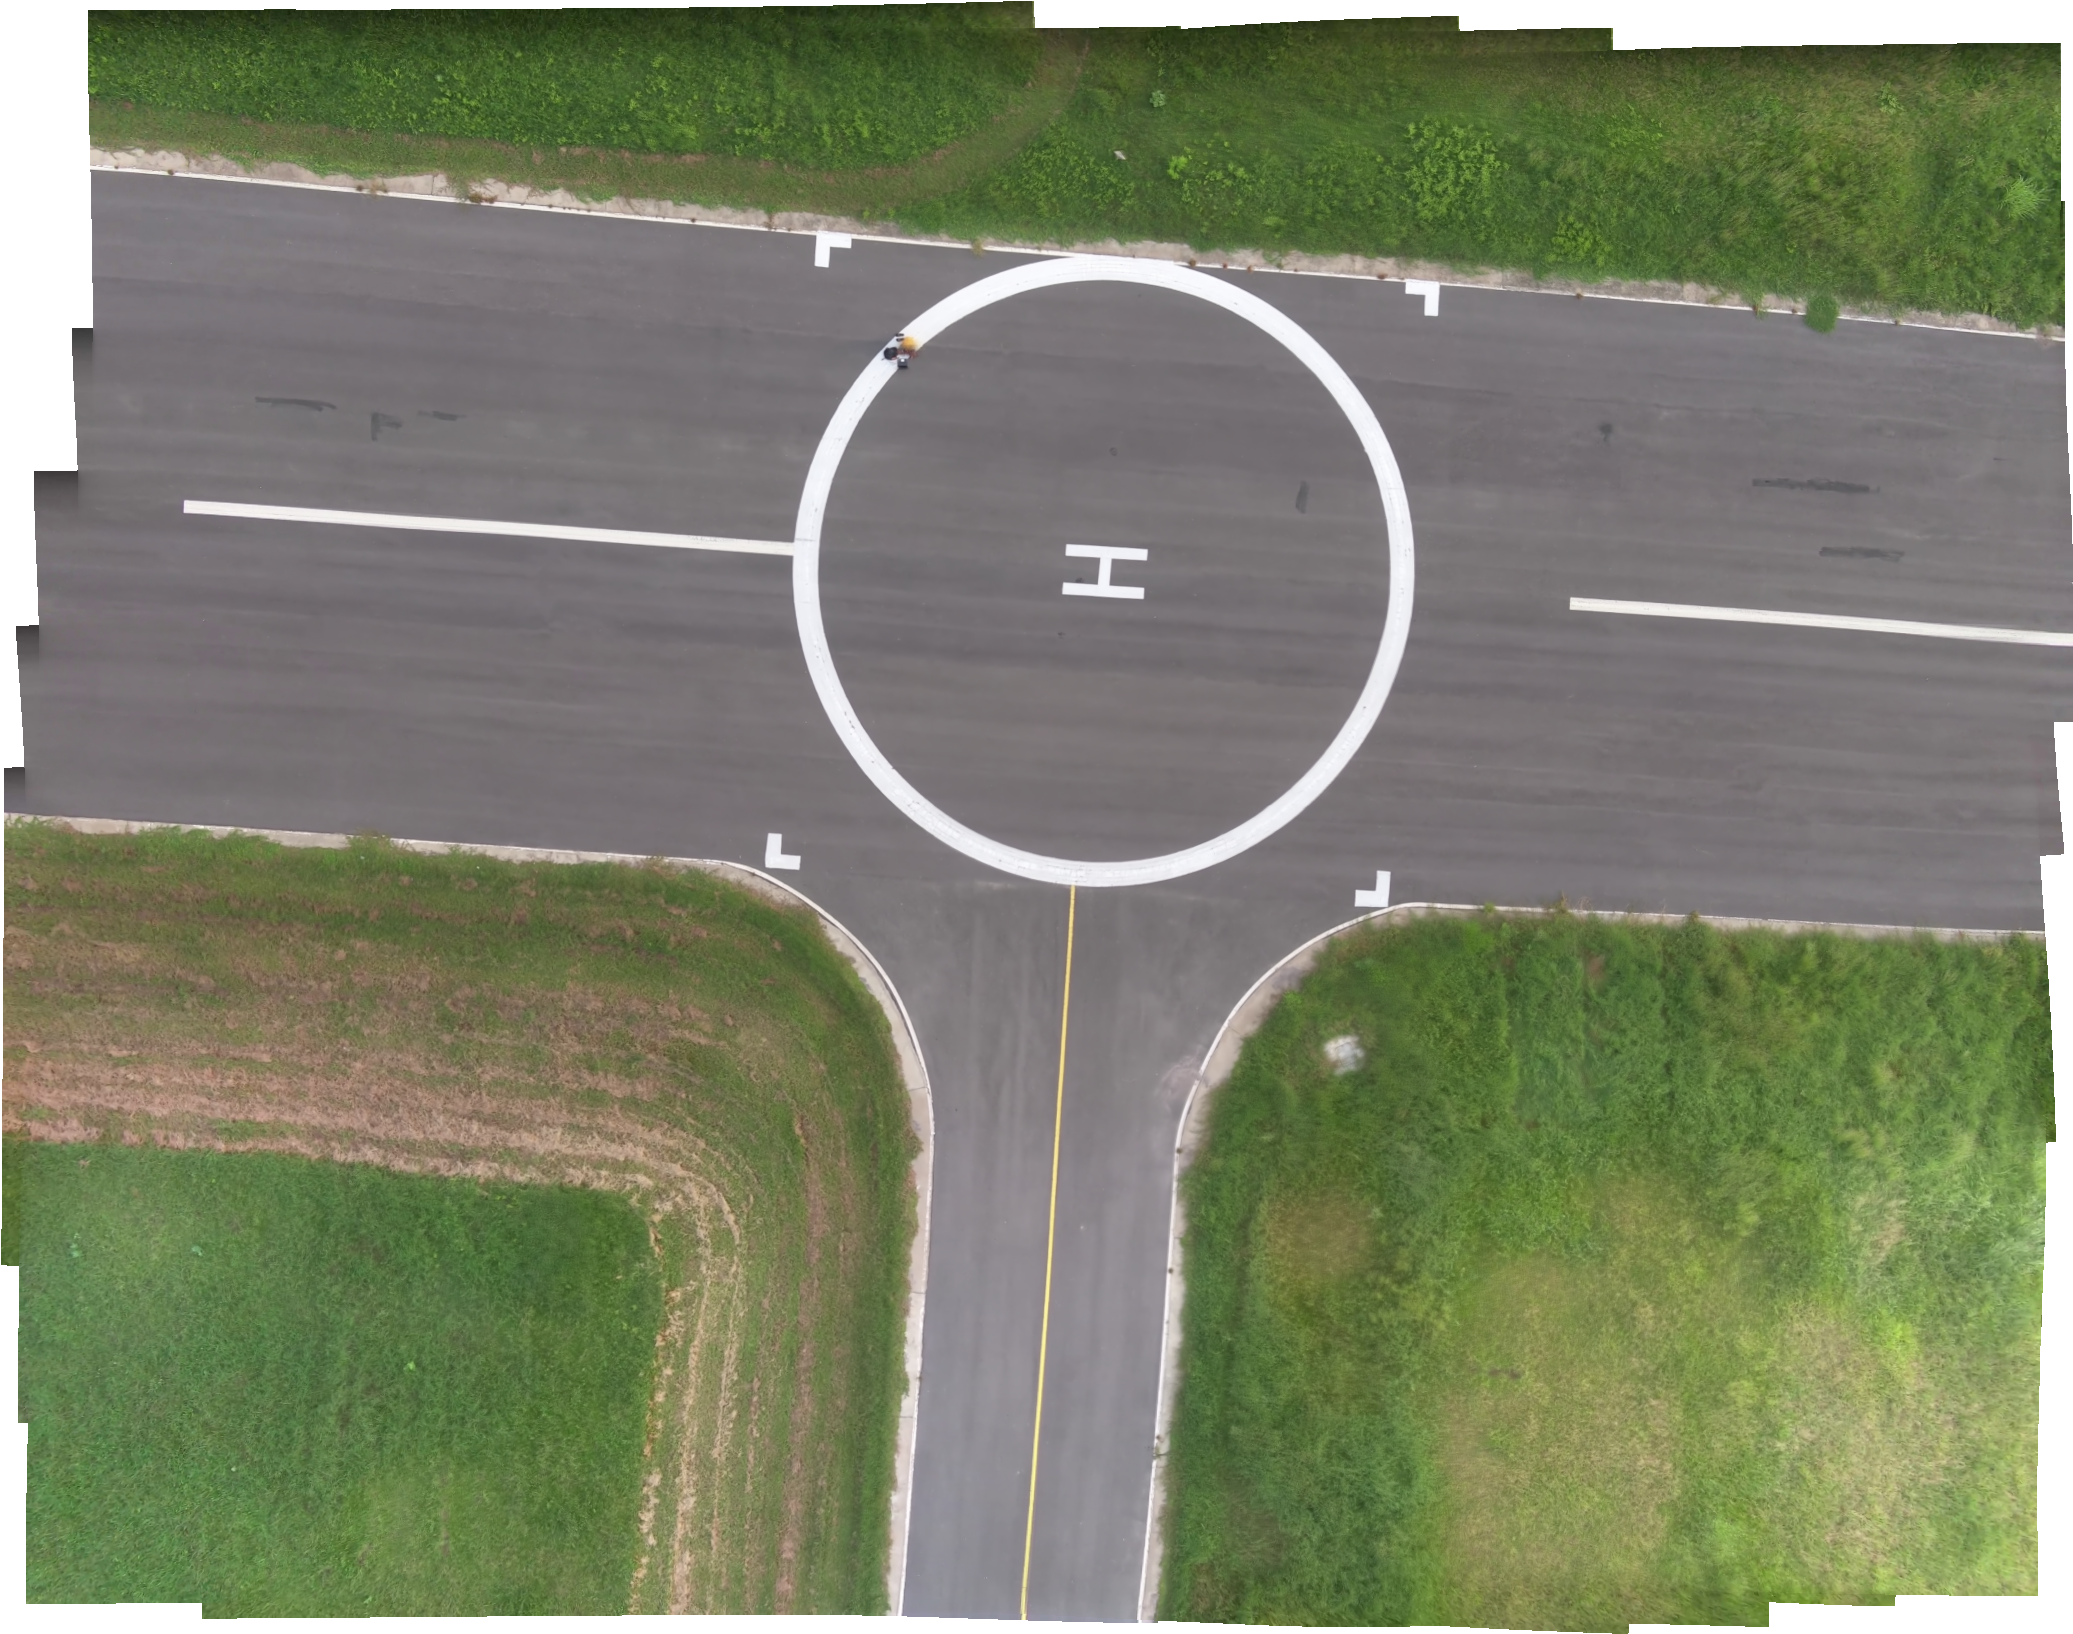
Developed multi-UAV coverage path planning for large-area mapping and adapted a mesh-optimization image-stitching method to produce natural-looking maps with low shape distortion.